今井 倫太 ( イマイ ミチタ )

Imai, Michita

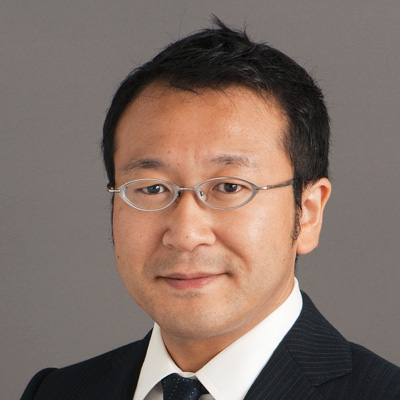
写真a

所属(所属キャンパス)

理工学部 情報工学科 ( 矢上 )

職名

教授

HP

外部リンク

経歴 【 表示 / 非表示 】

  • 1994年04月
    -
    1997年02月

    日本電信電話株式会社

  • 1994年08月
    -
    1997年02月

    日本電信電話株式会社 ヒューマンインタフェース研究所 画像通信研究部 配属

  • 1997年03月
    -
    2001年09月

    株式会社国際電気通信基礎技術研究所(ATR 知能映像通信研究所 研究員) 出向

  • 2001年10月
    -
    2002年03月

    株式会社国際電気通信基礎技術研究所 メディア情報科学研究所 研究員

  • 2002年04月
    -
    継続中

    慶應義塾大学理工学部情報工学科

学歴 【 表示 / 非表示 】

  • 1992年03月

    慶應義塾大学, 理工学部, 電気工学科

    大学, 卒業

  • 1994年03月

    慶應義塾大学, 理工学研究科, 計算機科学専攻

    大学院, 修了, 修士

学位 【 表示 / 非表示 】

  • 博士(工学), 慶應義塾大学, 課程, 2002年03月


研究分野 【 表示 / 非表示 】

  • 情報通信 / 知能ロボティクス

  • 情報通信 / 知能情報学

  • 人文・社会 / 認知科学

研究キーワード 【 表示 / 非表示 】

  • インタラクティブインテリジェンス

  • ヒューマン エージェント インタラクション

  • ヒューマン ロボット インタラクション


著書 【 表示 / 非表示 】

  • Web Intelligence and Intelligent Agents

    今井 倫太, InTech, Publishing, 2010年03月

  • ロボット情報学ハンドブック

    今井 倫太, ナノオプトニクスエナジー, 2010年03月

    担当範囲: 639-640, 674

論文 【 表示 / 非表示 】

  • Graph-Based Simultaneous Path and Foothold Planning for Multi-Limbed Intra-Vehicular Robots in Space Stations

    Masazumi Imai, Kentaro Uno, Toshinori Kuwahara, Kazuya Yoshida

    2026年09月

     概要を見る

    Robot-aided operations in space stations are essential for reducing the workload of astronauts and improving the efficiency of on-orbit activities. Multi-limbed intra-vehicular robots (MLIVRs) equipped with grappling end-effectors have emerged as a promising solution, as they can securely grasp pre-existing interfaces, such as handrails and seat tracks, thereby enabling stable locomotion and forceful manipulation in microgravity environments. Since graspable locations on these interfaces are spatially limited and discretely distributed, motion planning for MLIVRs must be addressed jointly with foothold planning. This paper presents a simultaneous path and foothold planning framework based on graph theory for MLIVRs. The proposed method efficiently searches for feasible stance sequences for a multi-limbed robot while satisfying manipulability constraints. The effectiveness of the proposed framework is validated through simulations in a 3D model of the International Space Station (ISS) cabin, demonstrating its capability to generate feasible and efficient locomotion plans in realistic intra-vehicular environments.

  • First Trigonometric Parallax Measurements with the KVN and VERA Array (KaVA)

    Nobuyuki Sakai, Daisuke Sakai, Noriyuki Kawaguchi, Shuangjing Xu, Bo Zhang, Taehyun Jung, Chungsik Oh, Jeong-Sook Kim, Soon-Wook Kim, Hiroshi Imai, Yuanwei Wu, Maria Rioja, Niu Liu, Zehao Lin, Ibnu Nurul Huda, Shuaibo Bian, Leonid Petrov, Jingdong Zhang, Takaaki Jike, Yoshiaki Tamura, Jeong Ae Lee, Hao Ding, Koichiro Sugiyama, Kazuhiro Hada, Kiyoaki Wajima, Kazuya Hachisuka, Mareki Honma, Kee-Tae Kim, Se-Jin Oh

    Publ. Astron. Soc. Japan (2026), psag117 2026年09月

     概要を見る

    To demonstrate the astrometric capability of the combined Korean VLBI (Very Long Baseline Interferometry) Network (KVN) and VLBI Exploration of Radio Astrometry (VERA) Array (KaVA), we conducted six-epoch VLBI observations of 22-GHz H$_{2}$O masers associated with the star-forming region W3(OH). Two atmospheric calibration methods, (1) GPS and (2) JMA (Japan Meteorological Agency) mesoscale analysis data, and two phase-reference sources were independently applied to the astrometric analysis. Trigonometric parallaxes of W3(OH) were successfully measured with all calibration strategies, including the first successful parallax measurement using JMA calibration. The combined-fit parallax is 0.497$\pm$0.024 mas, corresponding to a distance of 2.01$^{+0.10}_{-0.09}$ kpc. This value is consistent with the previous Very Long Baseline Array (VLBA) result of 0.489$\pm$0.017 mas. KaVA achieved a 55$\%$ higher signal-to-noise ratio in phase-referenced maps than VERA, in good agreement with theoretical expectations. These results suggest that KaVA will enable trigonometric parallax measurements of 22-GHz H$_2$O masers that are difficult to observe with VERA alone because of low flux densities and/or limited $uv$ coverage. A flux variation from 510\,$\pm$\,50 to 3900\,$\pm$\,400 Jy was detected in W3(OH) over a one-year observing campaign and is attributed to two nearby maser features separated by only $\sim$64 AU at 2.01 kpc. The brightest feature showed a decrease in linewidth with increasing peak flux density, consistent with unsaturated maser amplification, whereas no similar trend was found for the other feature, suggesting different responses to the same amplification conditions, possibly owing to differences in saturation state and internal velocity structure.

  • From Task Success to Productive Success: Evaluating Human-AI Collaboration by Quality and Cost

    Saki Imai, Mert İnan, Malihe Alikhani

    2026年09月

     概要を見る

    AI productivity is often measured by task completion time, economic value, or improvements in outcome quality. However, these measures usually treat collaboration as a black box where they capture what output was produced, but not the interaction cost required to produce it. Motivated by economics literature, we introduce a productivity-oriented framework for evaluating human-AI collaboration as outcome quality relative to interaction cost. Across two datasets spanning four tasks, we show that: (1) sessions with identical quality ratings can differ by up to 70 times in interaction cost; (2) quality-cost relationships vary by task, with some tasks rewarding extended interaction and others favoring fast convergence; (3) subjective user ratings are not reliable substitutes for productivity; and (4) productive sessions are characterized by agents probing earlier and users spending less effort repairing the interaction. By distinguishing productive success from costly success, our framework makes interactional cost visible and shows how dialogue analysis can inform the evaluation and design of AI systems.

  • A diagnostic system of 5.7 keV muon beam for muon accelerator

    M. Wada, M. Kimura, S. Aritome, E. Cicek, K. Futatsukawa, K. Hirai, M. Hoshiai, T. Iijima, Y. Imai, K. Inami, K. Ishida, S. Kamioka, Y. Kawase, A. Kondo, Y. Kondo, M. Lyu, T. Mibe, Y. Nagatani, Y. Nakazawa, S. Ogawa, Y. Oishi, M. Otani, N. Saito, K. Shimomura, K. Suzuki, T. Takayanagi, K. Ueda, S. Uetake, S. Yamamoto, T. Yamazaki, M. Yang

    2026年08月

     概要を見る

    Realization of a low-emittance muon beam through the acceleration of keV-scale muons requires the injection of a suitably matched beam into an accelerator, since beam mismatch can lead to emittance growth and reduced acceleration efficiency. In one such scheme, muons are first thermalized to room temperature and then injected into a linear accelerator. Non-destructive diagnostics are challenging because of the low energy and low intensity. We developed a compact low-energy muon diagnostic system compatible with the accelerator under construction at J-PARC. The system is designed to evaluate beam conditions required for precise tuning prior to acceleration. Commissioning with low-energy muon sources shows the system's capability to identify low-energy muon signals and measure beam profiles.

  • Coarse-to-Fine Registration of Jawbone CT and Intraoral Scan Data Using GeDi and ICP with Pseudo-IOS Ground Truth

    Sho Mitarai, Hikaru Kayo, Hisashi Ozaki, Yuichiro Imai, Megumi Nakao

    2026年08月

     概要を見る

    In digital dentistry and oral surgery, the registration of jawbone CT and intraoral scanner (IOS) data is essential for integrating internal bone structure with high-resolution dental surface geometry. However, this registration is challenging because the two modalities share only a limited region in common, and their true correspondence is generally unknown. This uncertainty has prevented rigorous quantitative evaluation of registration accuracy. In this study, we propose a pseudoIOS evaluation framework in which a point cloud emulating an intraoral scan is generated from CT data within the same coordinate frame, so that the transformation between them is known by construction and can serve as a true ground truth. Using this framework, we propose a coarse-to-fine registration method that combines a domain-generalizable local descriptor (GeDi) for initialization-independent global alignment with the iterative closest point (ICP) algorithm for local refinement, and also evaluate the influence of metal artifacts on registration. In experiments on seven cases, ICP alone frequently converged to local minima from a perturbed initial position, whereas GeDi$+$ICP maintained submillimeter mean absolute error (MAE) across all evaluated jaw and artifact conditions (0.55-0.69 mm). A three-way repeated-measures analysis confirmed that GeDi$+$ICP was significantly more accurate than GeDi alone. Metal artifacts had a statistically detectable overall effect, but their absolute impact on GeDi$+$ICP was small.

全件表示 >>

KOARA(リポジトリ)収録論文等 【 表示 / 非表示 】

総説・解説等 【 表示 / 非表示 】

  • Blended Realityにより遠隔コミュニケーションを支援するアバターの設計

    金井 祐輔, 大澤 博隆, 今井 倫太

    人工知能学会全国大会論文集 (人工知能学会)  27   1 - 3 2013年

    ISSN  1347-9881

  • 1P1-P06 Pygmy : 指輪型擬人化ロボットの開発(アミューズメント・エンタテイナーロボット)

    尾形 正泰, 杉浦 裕太, 大澤 博隆, 今井 倫太

    ロボティクス・メカトロニクス講演会講演概要集 (一般社団法人日本機械学会)  2012   "1P1 - P06(1)"-"1P1-P06(2)" 2012年05月

     概要を見る

    The human hand is used to express characters by its posure. Pygmy is an anthropomorphic device that magnifies the finger expressions. It is based on the concept of hand anthropomorphism and uses finger movements to create the anthropomorphic effect. Wearing the device is similar to having eyes and a mouth on the hand; the wearer's hand spontaneously expresses a presence of living thing with the emotions conveyed by the eyes and mouth. Interactive manipulation by controllers and sensors make the hand look animated. We developed small parts of robotic eye and mouth with electromagnetic motor. We observed that the character animated with the device provided user collaboration and interaction as though there were a living thing on the user's hand.

研究発表 【 表示 / 非表示 】

  • Where Should Robots Talk?: Spatial Arrangement Study from a Participant Workload Perspective

    Takahiro Matsumoto

    IEEE/ACM HRI’18, 

    2018年03月
    , 

    口頭発表(一般)

  • Is a Robot a Better Walking Partner If It Associates Utterances with Visual Scenes?

    Satoru Satake

    [国際会議]  the 2017 ACM/IEEE International Conference on Human-Robot Interaction, 

    2017年03月
    , 

    口頭発表(一般)

  • An Implementation of Working Memory Using Stacked Half Restricted Boltzmann Machine: Toward to Restricted Boltzmann Machine-Based Cognitive Architecture

    Masahiko Osawa

    [国際会議]  The 23rd International Conference on Neural Information Processing, 

    2016年10月
    , 

    口頭発表(一般)

  • The Use of The BDI Model As Design Principle for A Migratable Agent

    Mamoru Yamanouchi

    [国際会議]  The 4th International Conference on Human-Agent Interaction, 

    2016年10月
    , 

    口頭発表(一般)

  • A Study on Controlling Method for an Autonomous Personal Vehicle Based On User’s Heart Rate Variability

    Taichi Sono

    [国際会議]  the IEEE International Symposium on Robot and Human Interactive Communication, 

    2016年08月
    , 

    口頭発表(一般)

全件表示 >>

競争的研究費の研究課題 【 表示 / 非表示 】

  • 対ロボット認知に基づくインタラクションの「間」の実践的意味づけモデル

    2016年04月
    -
    2020年03月

    文部科学省・日本学術振興会, 科学研究費助成事業, 今井 倫太, 基盤研究(B), 補助金,  研究代表者

  • 人の適応性を支える環境知能システムの構築

    2014年07月
    -
    2019年03月

    文部科学省・日本学術振興会, 科学研究費助成事業, 今井 倫太, 新学術領域研究(研究領域提案型), 補助金,  研究代表者

受賞 【 表示 / 非表示 】

  • 2013年度論文賞

    2014年06月, 人工知能学会, エージェントのインタラクション戦略探索のための没入型発見法

    受賞区分: 国内学会・会議・シンポジウム等の賞

  • Best Note Honorable Mention

    2012年05月, ACM SIG-CHI

  • 日本人工知能学会全国大会優秀論文賞

    今井 倫太, 1999年12月, 日本人工知能学会


担当授業科目 【 表示 / 非表示 】

  • 人間・社会システム情報科学修士研究A2

    2026年度

  • 在外国際活動Ⅲ

    2026年度

  • 情報工学輪講

    2026年度

  • 計算理論

    2026年度

  • 在外国際活動Ⅳ

    2026年度

全件表示 >>


社会活動 【 表示 / 非表示 】

  • ACM

    2002年05月
    -
    継続中
  • 国際電気通信基礎技術研究所

    2002年04月
    -
    継続中

所属学協会 【 表示 / 非表示 】

  • ACM HRI2010, 

    2009年08月
    -
    2010年03月
  • HAI 2009, 

    2009年04月
    -
    2009年12月
  • IEEE RO-MAN 2009, 

    2009年03月
    -
    2009年09月
  • IEEE RO-MAN 2009, 

    2009年02月
    -
    2009年09月
  • ISCR 2009, 

    2009年01月
    -
    2009年08月

全件表示 >>

委員歴 【 表示 / 非表示 】

  • 2009年08月
    -
    2010年03月

    Program Committee, ACM HRI2010

  • 2009年04月
    -
    2009年12月

    実行委員, HAI 2009

  • 2009年03月
    -
    2009年09月

    IDEA Session Organizer, IEEE RO-MAN 2009

  • 2009年02月
    -
    2009年09月

    Program Committee, IEEE RO-MAN 2009

  • 2009年01月
    -
    2009年08月

    Program Committee, ISCR 2009

全件表示 >>